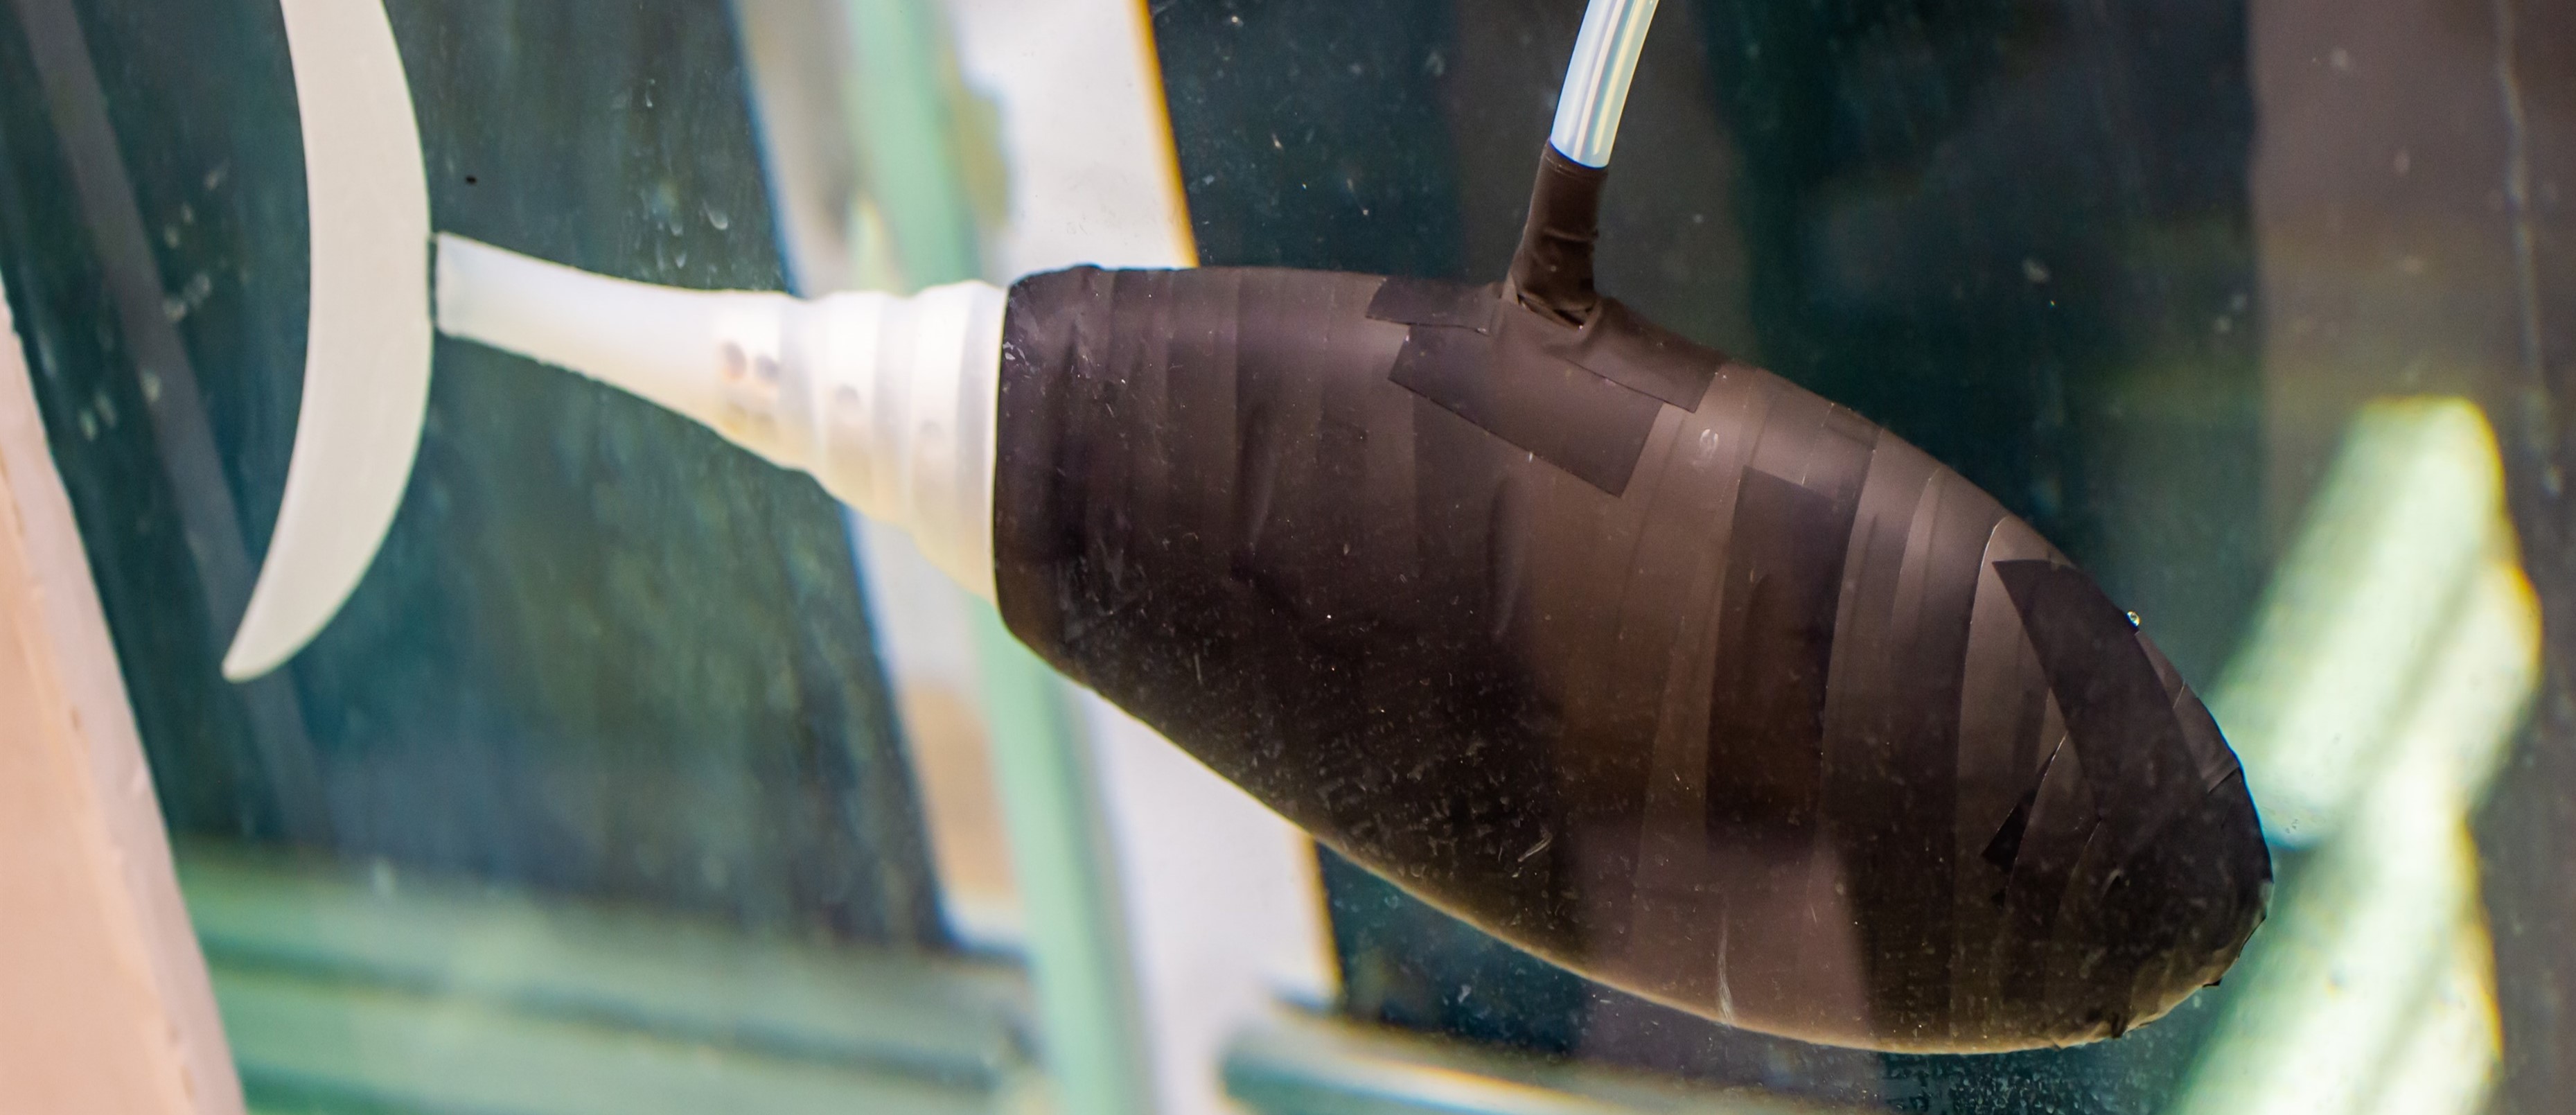
Design & Development of Robotics Fish (Capstone Project)
Dapeng Wang, Bowen Su, Wentao Jiangm, Hui Tang
- A robotic fish with simple structure could achieve multi-dimensional motions based on an open-scourced design-"OpenFish".(Sander C.van den Berg et.al.).
- Supervised by Dr. Hui Tang.
- This fish could achieve functions of thrusting, simple turning, lifting & diving.
- My contributions:
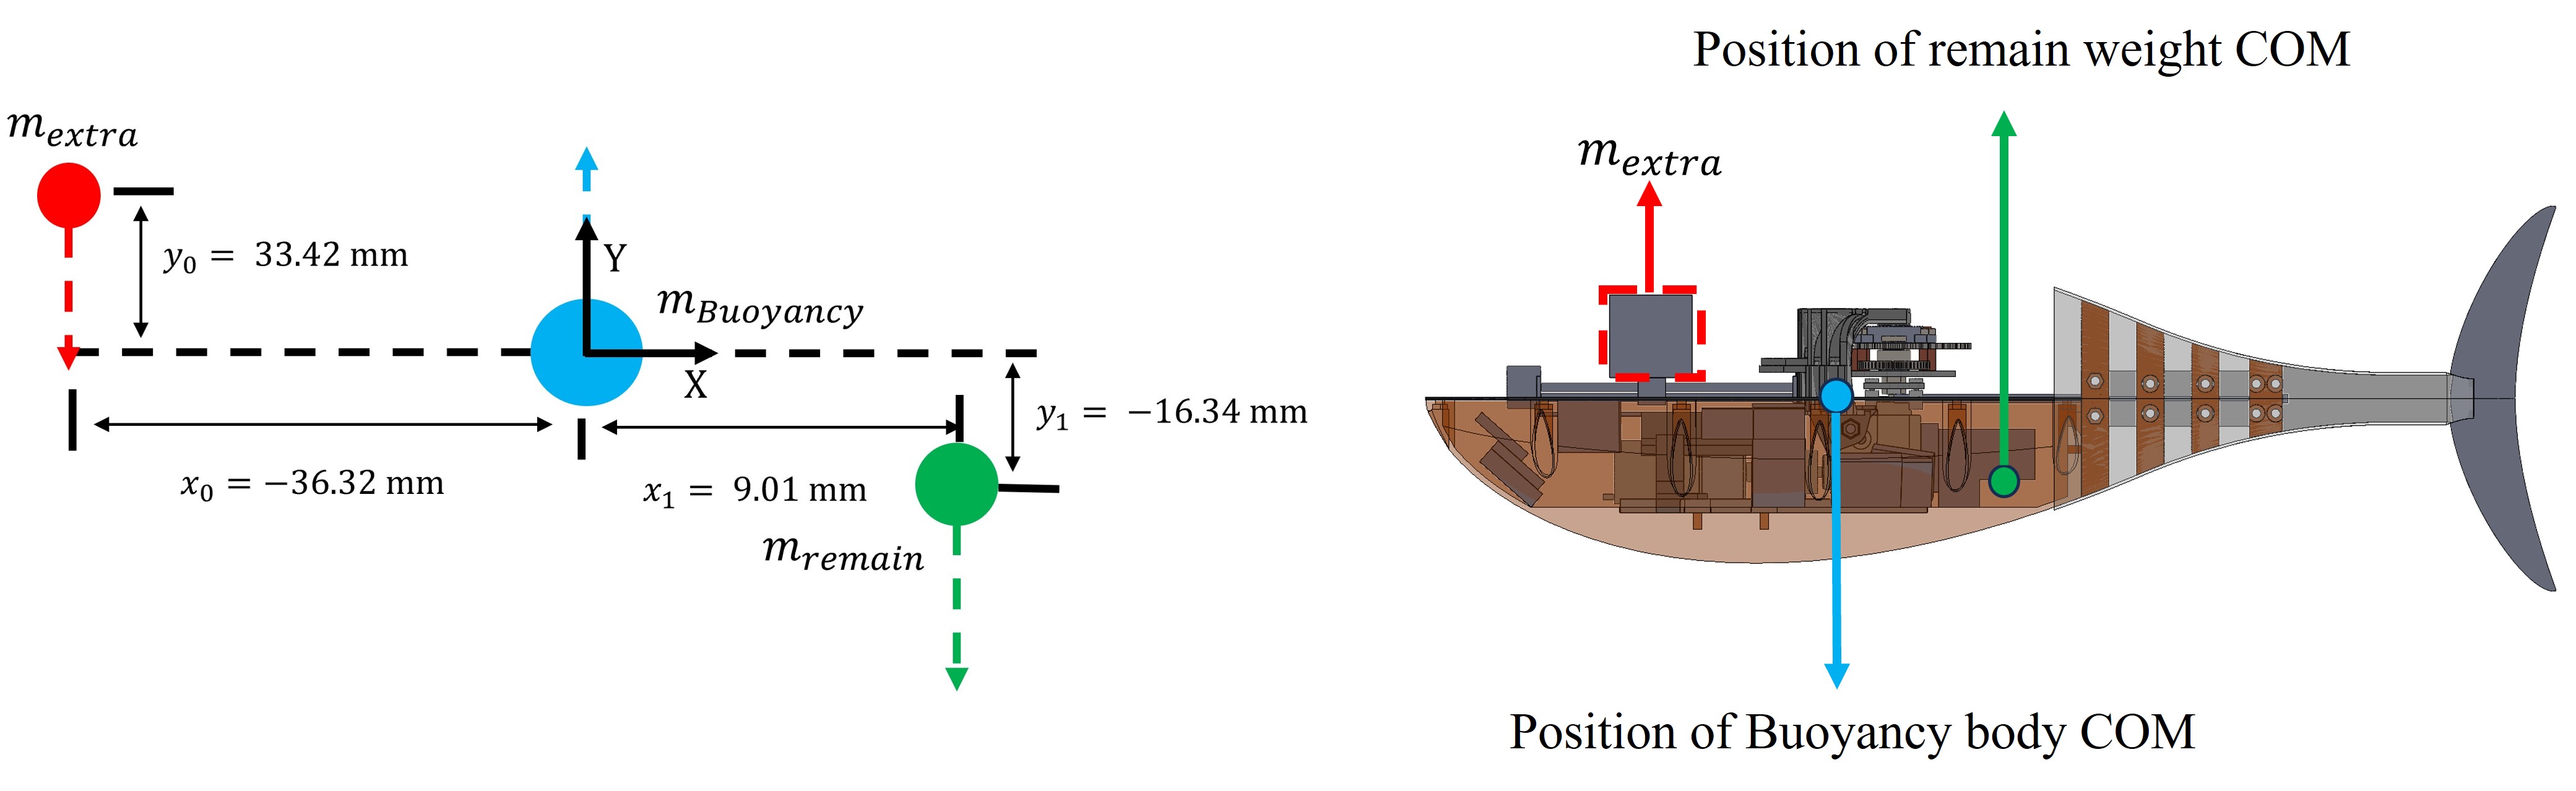
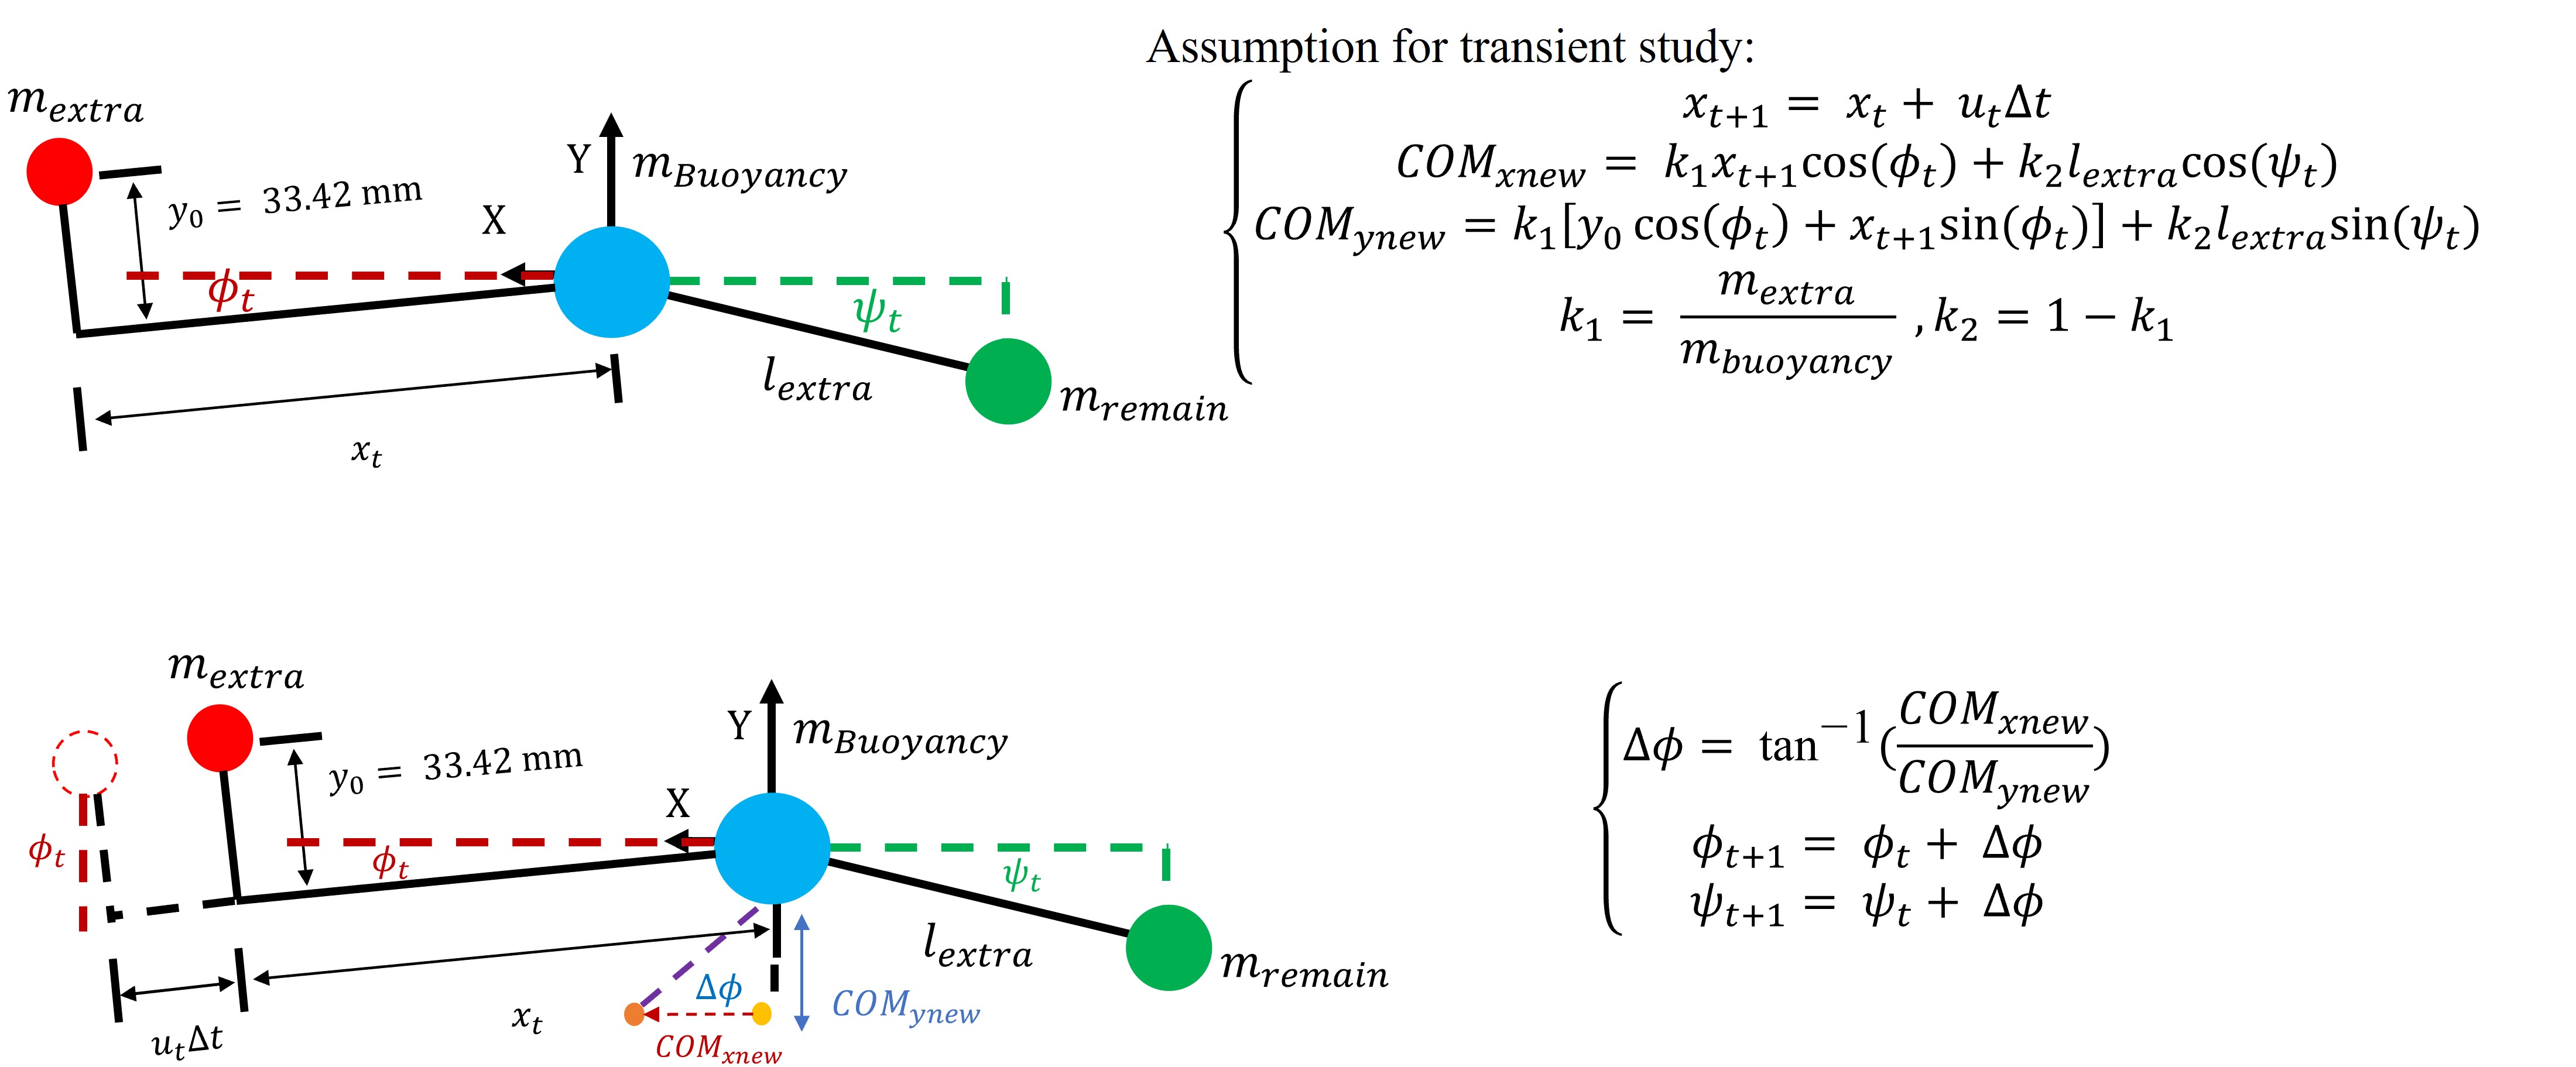
- Successfully derive the dynamics model of lifting & diving functions and fish tail.
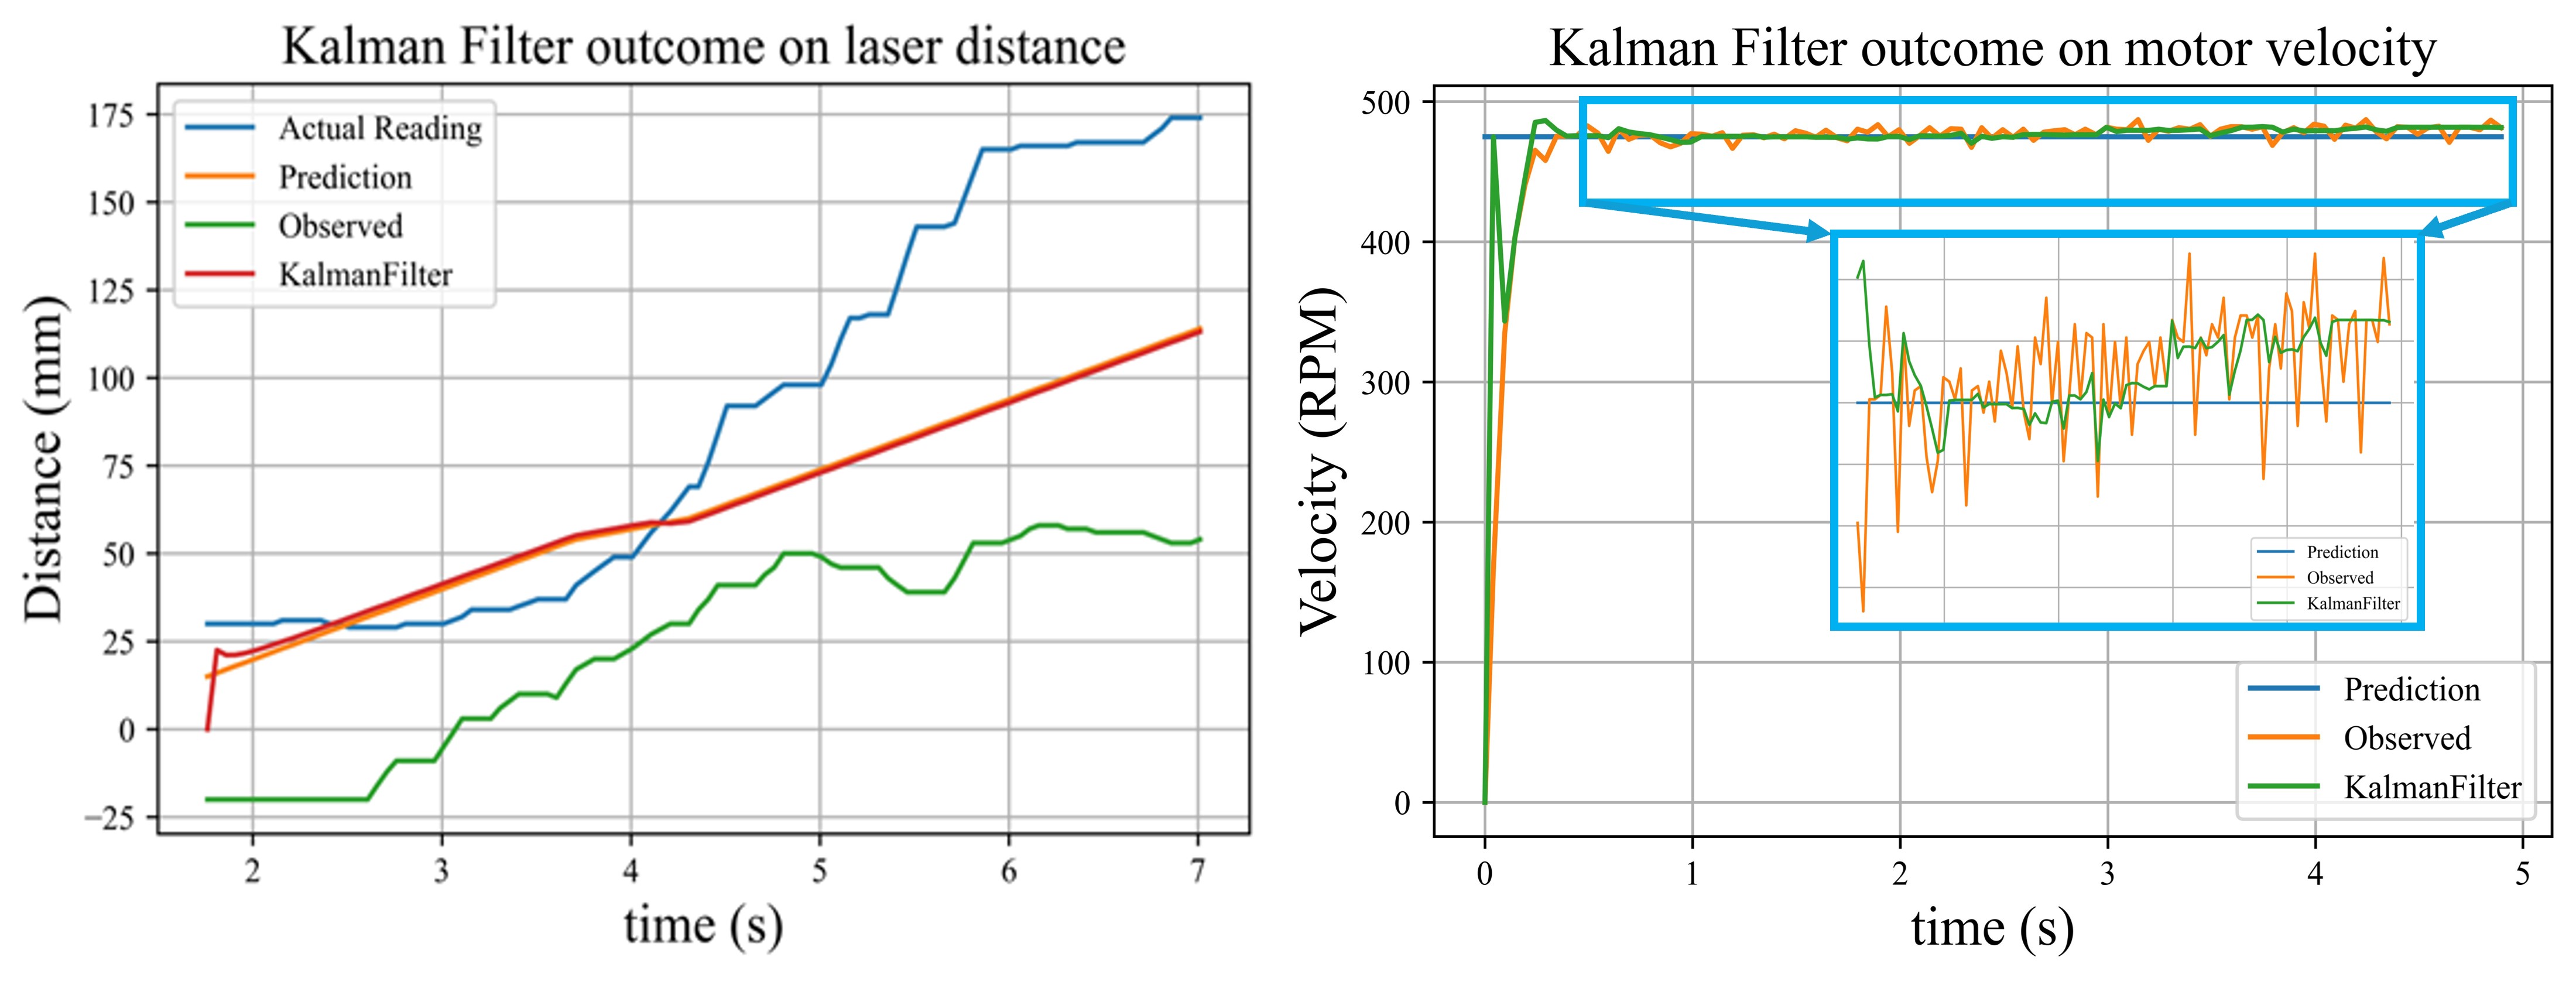
- Signal Processing in feedback control of lifting & diving
- Design and Build offline Kalman Filter for thrust speed control and altitude management
- Reveived A+ in Final Assessment Results.